 GrabCAD
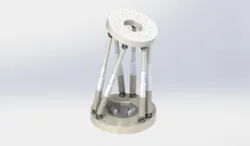
Modern Stewart Platform
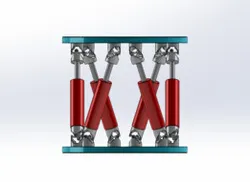
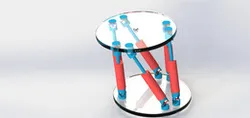
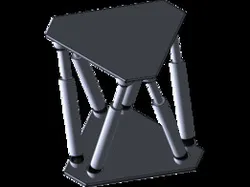
Today I decided to build a very special mechanism called the Stewart platform. This mechanism caught my attention when I first started the course Foundations of Robot Motion, which is posted by Northwestern University.
By calculating the mobility or DOF of this system, Grubler's formula tells us that the Stewart platform has 6 degrees of freedom. The top platform can be moved with all 6 degrees of freedom of a rigid body. There are limits to the range of motion, of course, but these limits do not reduce the number of degrees of freedom, which is unique.
Thanks to SOLIDWORKS' Inspection workshop and PhotoView360 for the realistic visualization of the 3D experience.
"Real courage is doing the right thing when nobody's looking."
Please, if you need more information about the model do not hesitate to contact us here on GrabCAD or on [email protected]
ENJOY.
Direct link to the original creator's page
More from Haytam Amhidi
Similar Models
Model Specifications
Frequently Asked Questions
Where is Modern Stewart Platform published?
This model is published by its creator on GrabCAD. STLFinder only indexes it: the "View on GrabCAD" button above opens the original page, where the creator shares the RENDERING, SNAGIT, SOLIDWORKS files under their own license.
What 3D printer can I use for this model?
This model is compatible with most FDM 3D printers (Creality Ender 3, Prusa MK3S+, Bambu Lab, etc.) and resin printers (Elegoo, Anycubic). Check the original page for recommended print settings and materials.
Is this 3D model free?
Yes, the creator shares it at no cost on GrabCAD. Some creators accept tips or donations.
Can I modify this file?
Check the license (see original page) on the original GrabCAD page. Most STL files can be modified using free software like Blender, TinkerCAD, or Meshmixer.