 GrabCAD
Robotic Arm
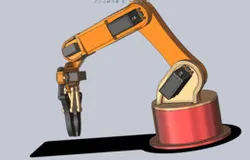
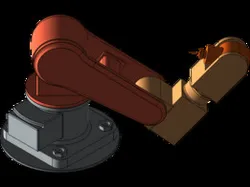
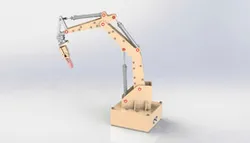
This 3D model represents a multi-axis industrial robotic arm designed and modeled in SolidWorks. The assembly consists of a rigid base platform supporting a rotational joint, enabling full 360-degree horizontal motion. The arm structure is segmented into multiple articulated links connected through servo-driven rotational joints, allowing controlled vertical and angular movement.
Each major joint is powered using mounted servo motors, accurately positioned to simulate realistic kinematic motion. The forearm section extends from the main arm and connects to a precision mechanical gripper. The gripper mechanism features interlocking gears ensuring synchronized finger movement for stable gripping and controlled handling of components.
The model demonstrates structural robustness, mechanical feasibility, and functional motion design typically found in robotic automation systems used in manufacturing, pick-and-place operations, and educational robotics projects. The assembly highlights proper constraint application, realistic geometry, and component interaction within the SolidWorks environment.
Direct link to the original creator's page
Also Available On
More from Dinesh Kumar
Similar Models

Model Specifications
Frequently Asked Questions
Where is Robotic Arm published?
This model is published by its creator on GrabCAD. STLFinder only indexes it: the "View on GrabCAD" button above opens the original page, where the creator shares the RENDERING, SOLIDWORKS files under their own license.
What 3D printer can I use for this model?
This model is compatible with most FDM 3D printers (Creality Ender 3, Prusa MK3S+, Bambu Lab, etc.) and resin printers (Elegoo, Anycubic). Check the original page for recommended print settings and materials.
Is this 3D model free?
Yes, the creator shares it at no cost on GrabCAD. Some creators accept tips or donations.
Can I modify this file?
Check the license (see original page) on the original GrabCAD page. Most STL files can be modified using free software like Blender, TinkerCAD, or Meshmixer.