 GrabCAD
Robotic Arm
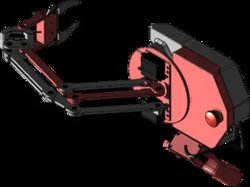
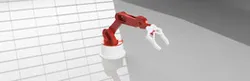
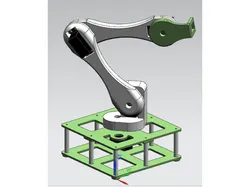
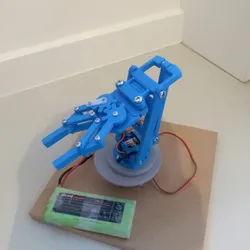
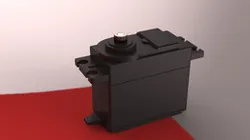
Here is my first prototype for a desktop sized robotic arm. Currently, it has 4 degrees of freedom and is controlled by potentiometers on a custom remote control. I chose to use an Arduino to process the analog inputs from the potentiometers and to send the PWM signal outputs to the servos, since it's only being controlled via remote for now. I plan to expand this project by integrating the mechanics I have built here with the ROS environment to create an automated process for this little guy.
Specifications:
Name: Albert
Type: 4 bar linkage - 5 DOF
Shoulder Servo Torque: 35kg-cm at 7.2v*
Elbow Servo Torque: 35kg-cm at 7.2v*
Wrist Servo Torque: 3.3kg-cm at 4.8v*
Finger Servo Torque: 1.8kg-cm at 5v*
Waist Servo Torque: 16.5kg-cm at 9v*
Operating Voltage: 7.2v-(two 18650 cells) / 5v-(from Microcontroller)
Direct link to the original creator's page
Also Available On
More from Marc Maurette

Similar Models

Model Specifications
Frequently Asked Questions
Where is Robotic Arm published?
This model is published by its creator on GrabCAD. STLFinder only indexes it: the "View on GrabCAD" button above opens the original page, where the creator shares the RENDERING, STEP / IGES files under their own license.
What 3D printer can I use for this model?
This model is compatible with most FDM 3D printers (Creality Ender 3, Prusa MK3S+, Bambu Lab, etc.) and resin printers (Elegoo, Anycubic). Check the original page for recommended print settings and materials.
Is this 3D model free?
Yes, the creator shares it at no cost on GrabCAD. Some creators accept tips or donations.
Can I modify this file?
Check the license (see original page) on the original GrabCAD page. Most STL files can be modified using free software like Blender, TinkerCAD, or Meshmixer.